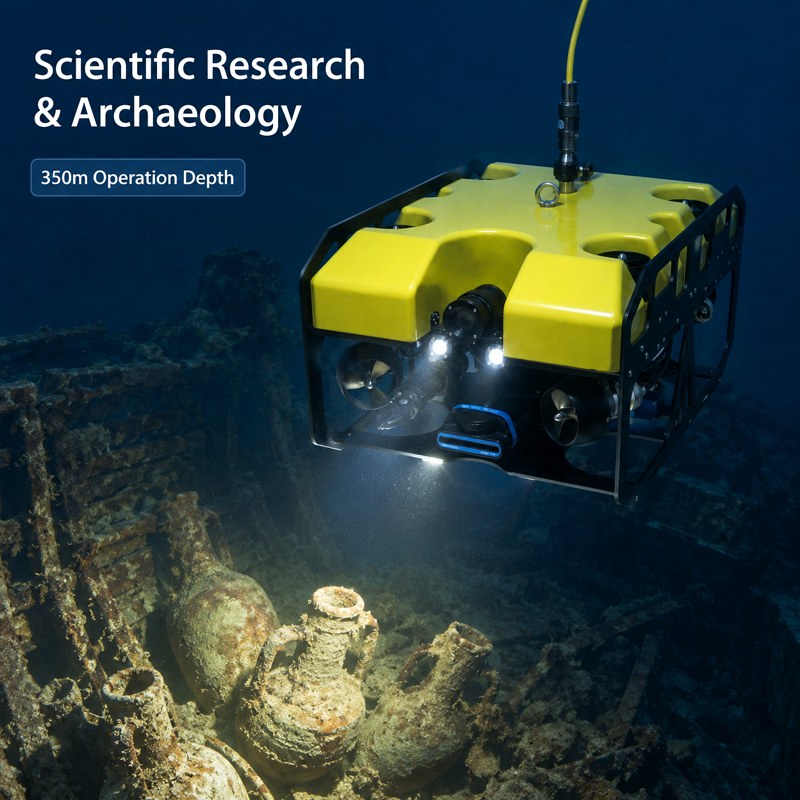
XHX-ROV-R40 Underwater Search and Rescue Robot for Deep-Water Operations

XHX-ROV-R40 Underwater Search and Rescue Robot for Deep-Water Operations

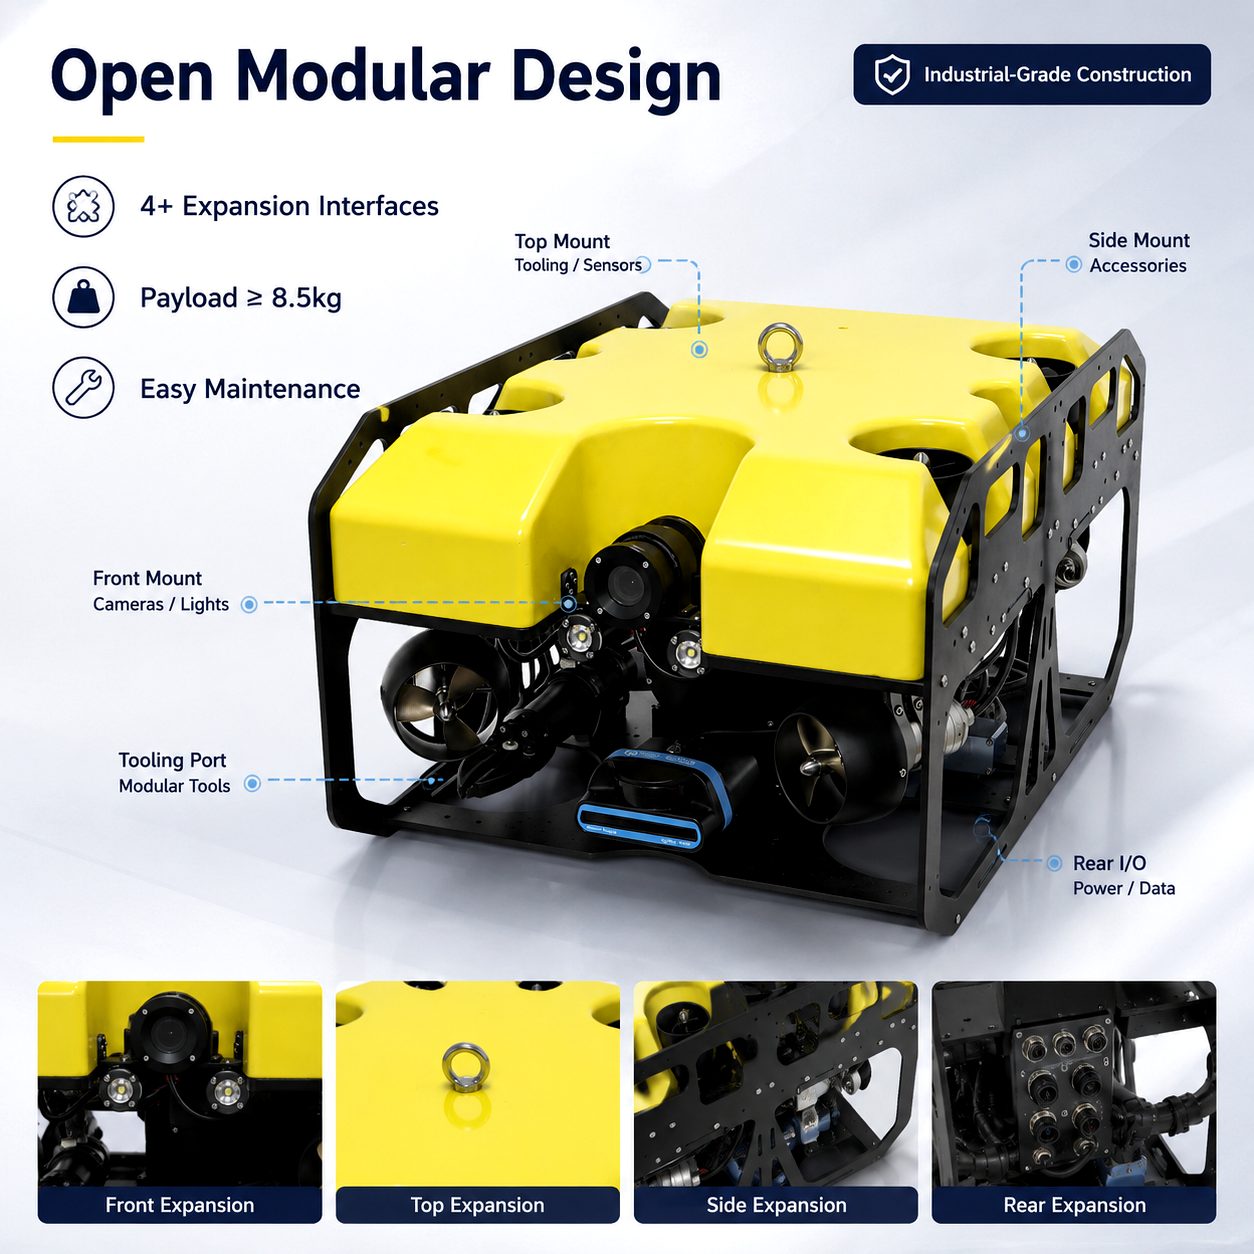
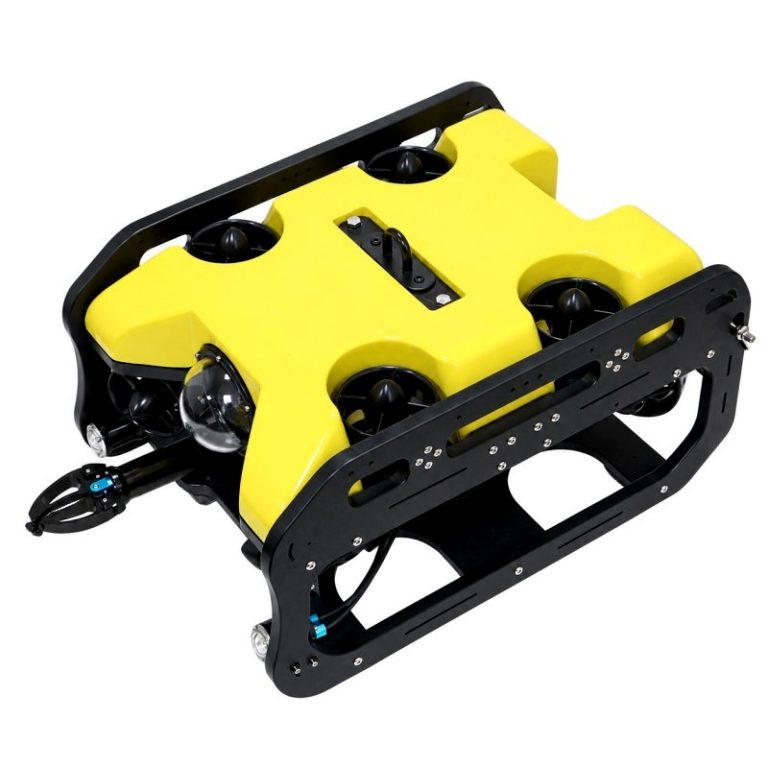
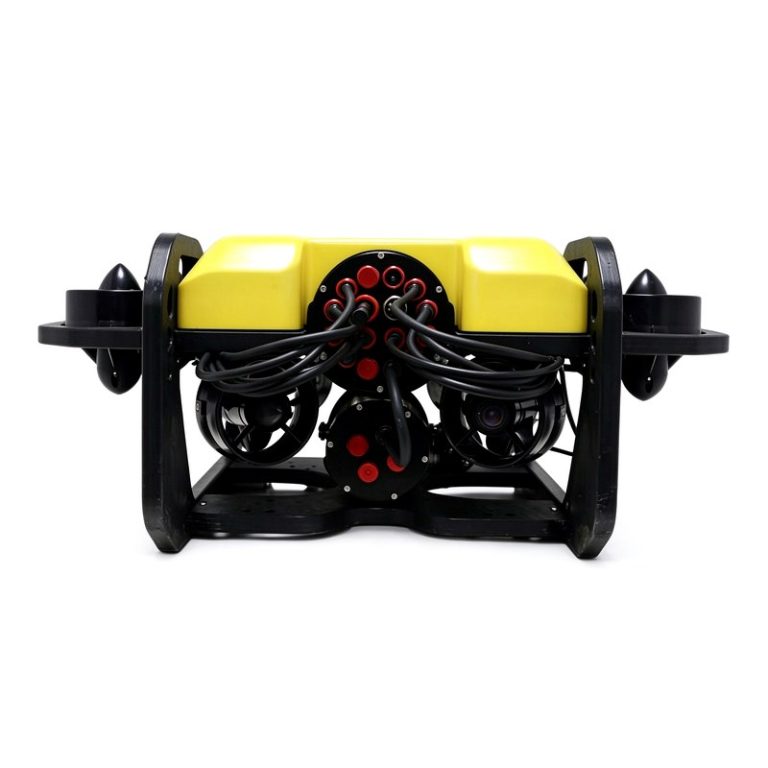
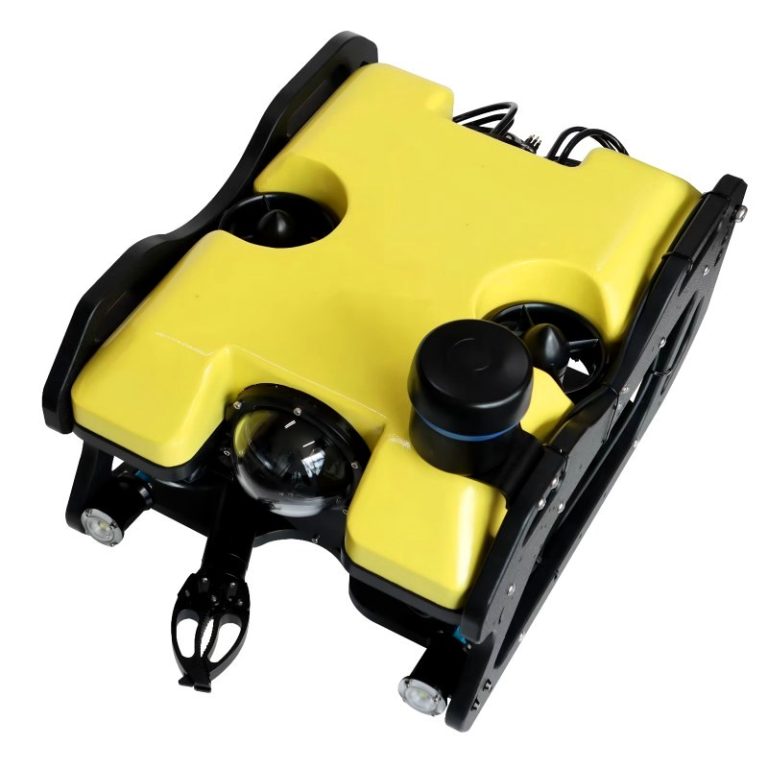
The XHX ROV R40 is a shore-powered, industrial-grade remotely operated underwater vehicle designed for underwater inspection, observation, and data collection. Its open modular aluminum alloy frame provides a stable platform for routine operations and allows users to add compatible equipment such as manipulators, sonar systems, and environmental sensors.

Inquiry
XHX-ROV-R40 Underwater Search and Rescue Robot for Deep-Water Operations XHX-ROV-R40 Underwater Search and Rescue Robot for Deep-Water Operations XHX-ROV-R40 Underwater Search and Rescue Robot for Deep-Water Operations XHX-ROV-R40 Underwater Search and Rescue Robot for Deep-Water Operations

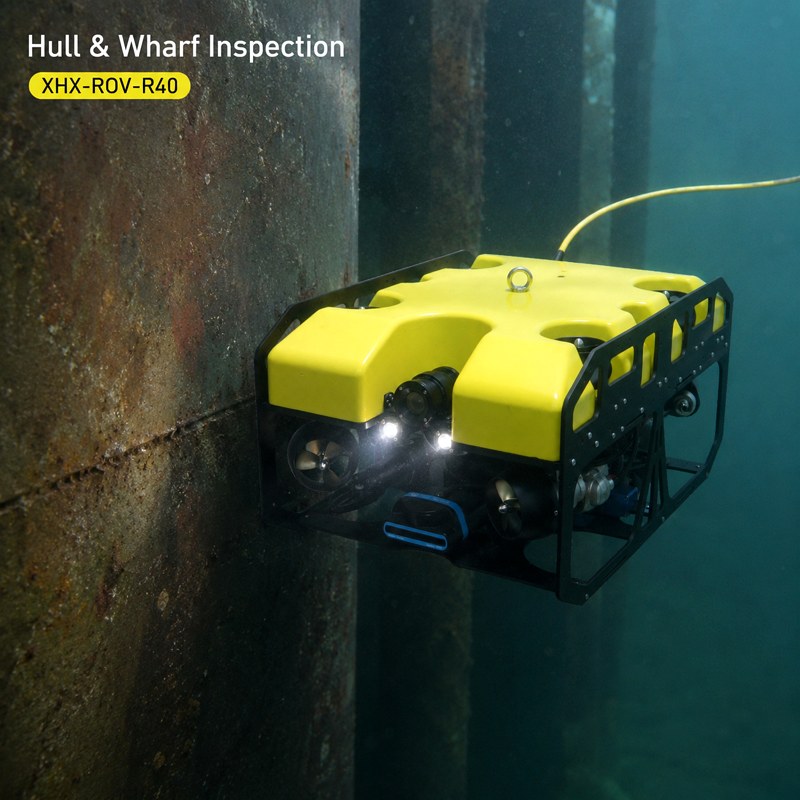
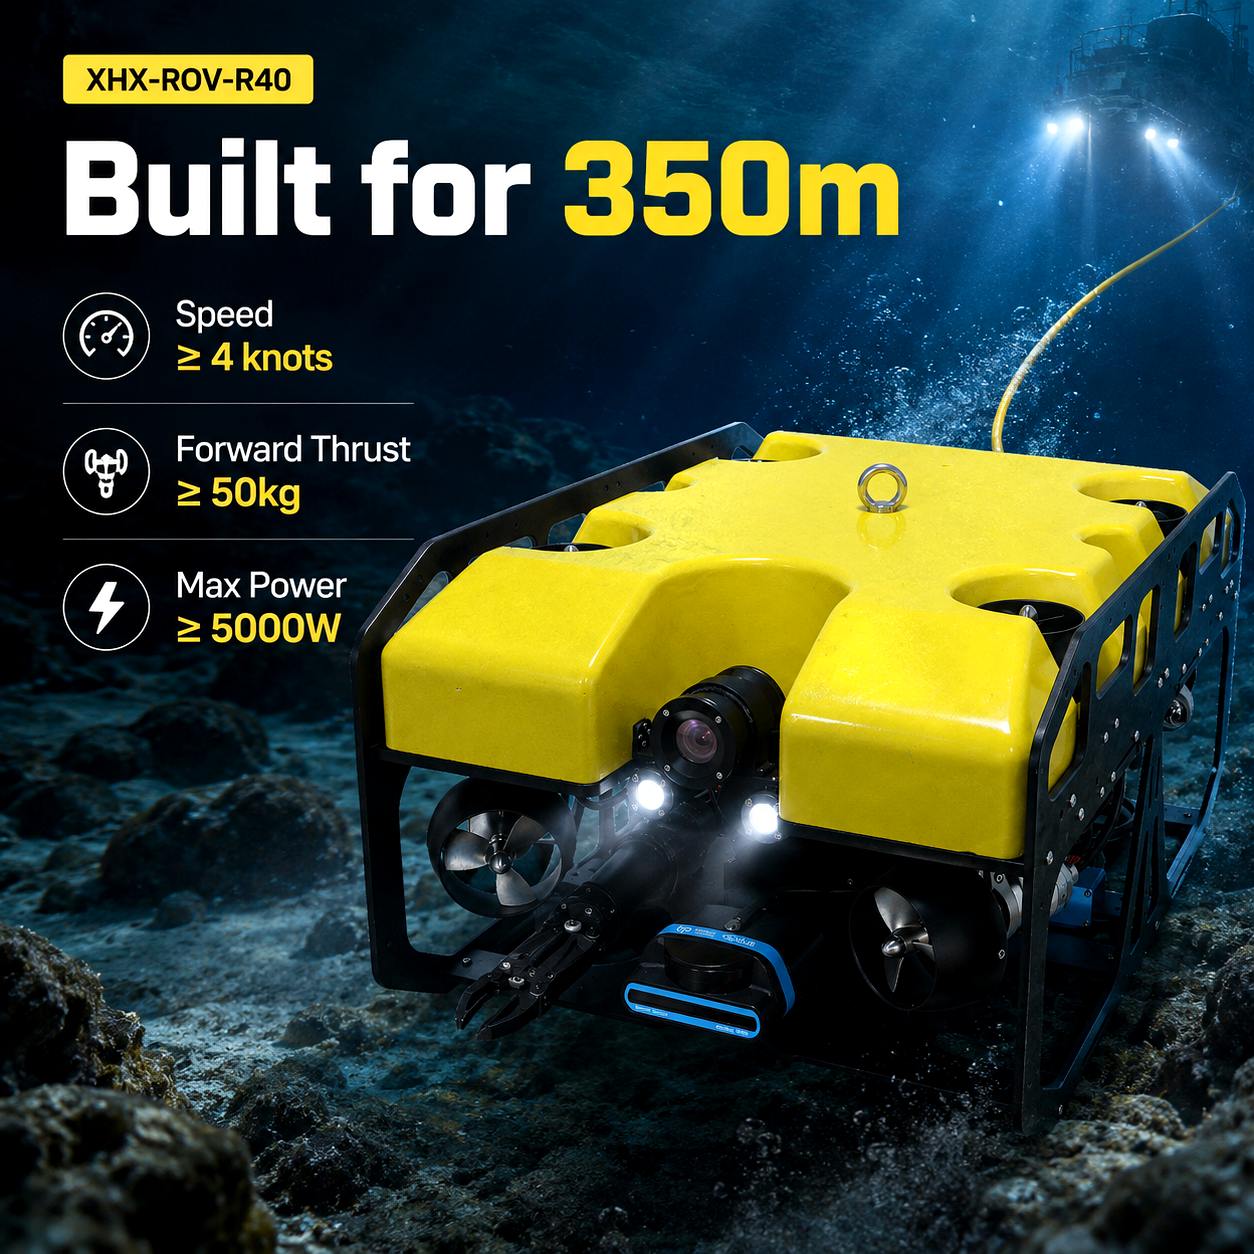
The XHX ROV R40 is a shore-powered, industrial-grade underwater vehicle for inspection, observation, and data collection. Rated for depths up to 350 meters, its open modular aluminum-alloy frame supports work in reservoirs, rivers, coastal areas, ports, and research sites.

Operational Highlights

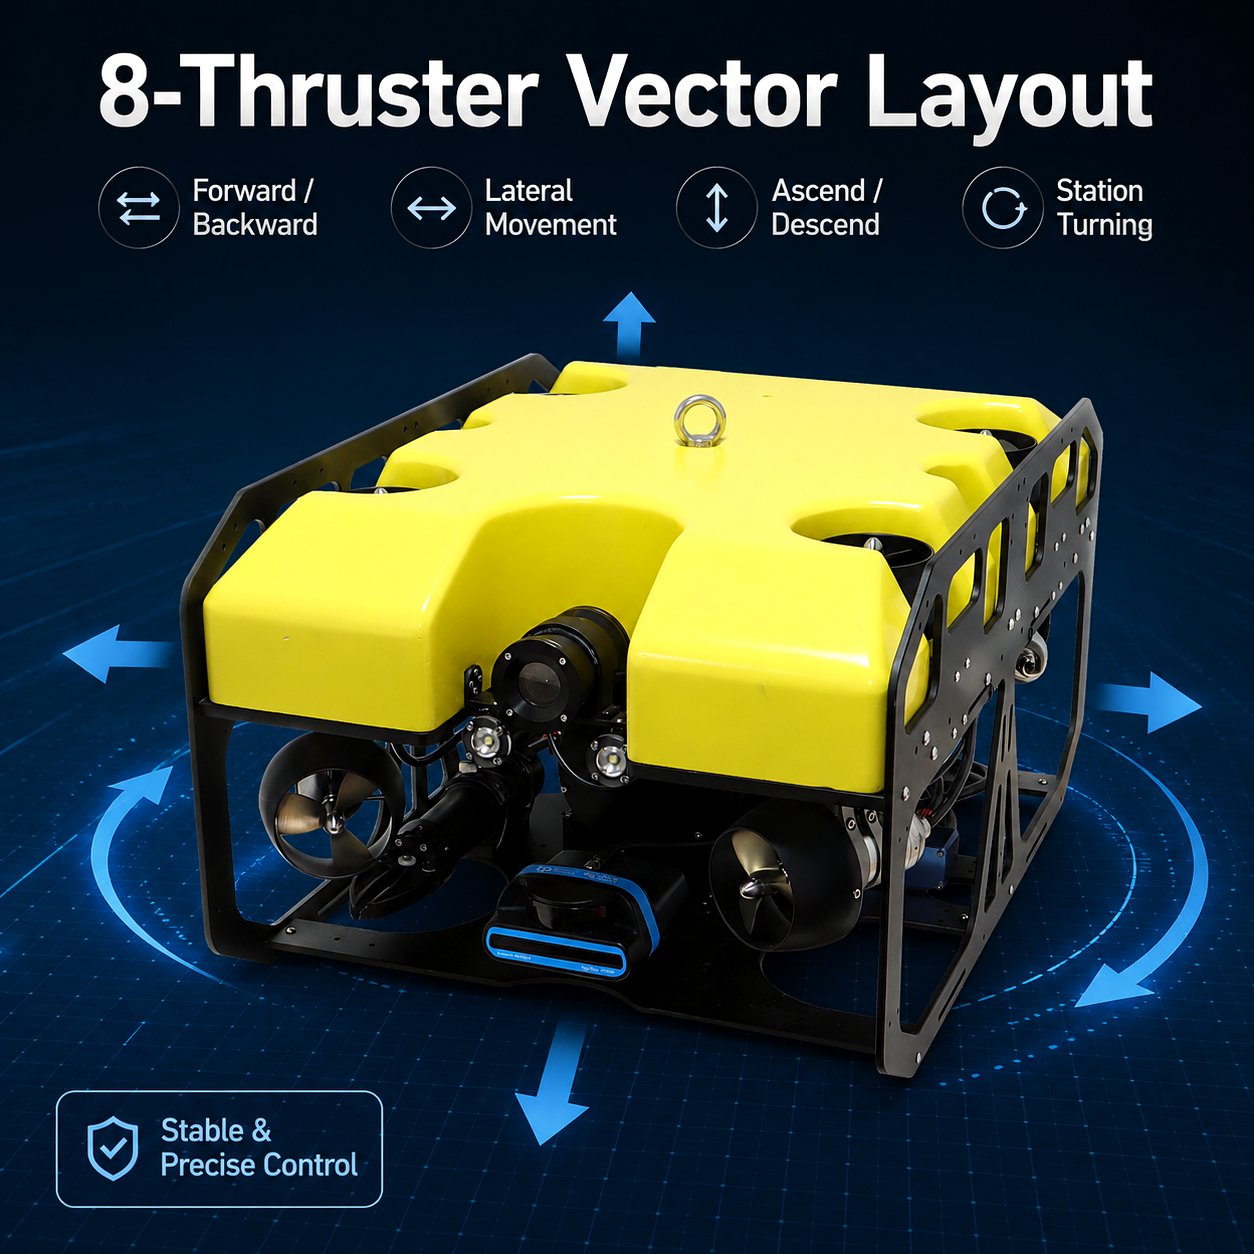
01. Eight-Thruster Maneuvering

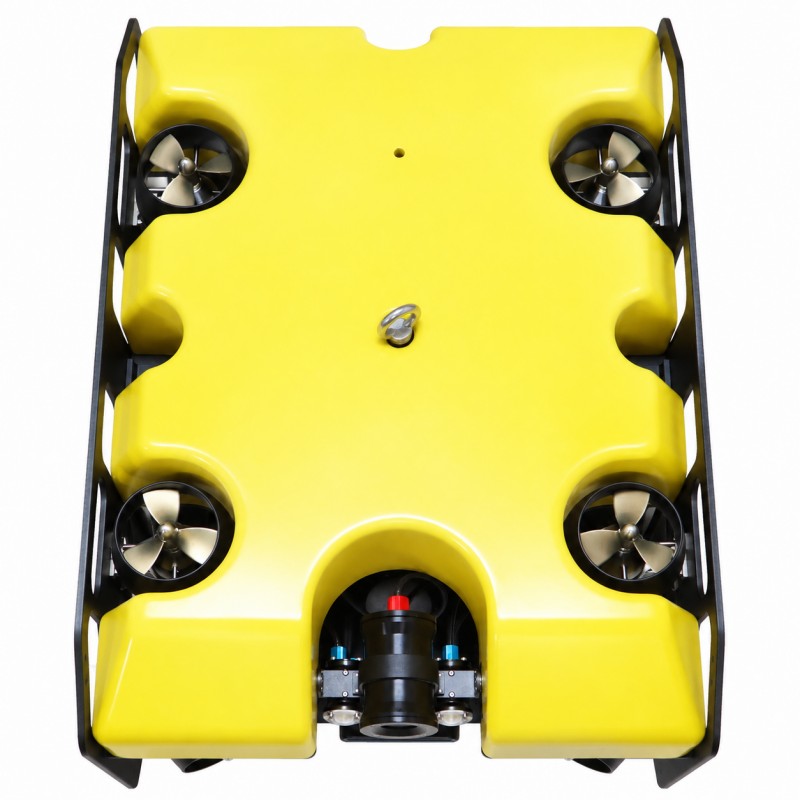
Eight T300S thrusters support forward, reverse, lateral, and vertical travel as well as turning, helping operators approach structures and maneuver in confined locations. Maximum forward speed is 2 m/s.

02. Continuous Shore Power

Power is supplied from shore through the umbilical rather than relying on onboard battery capacity. Cable lengths are available from 25 to 300 m; the cable has a stated working strength of 100 kg and breaking strength of 300 kg.

03. Low-Light Visual Inspection

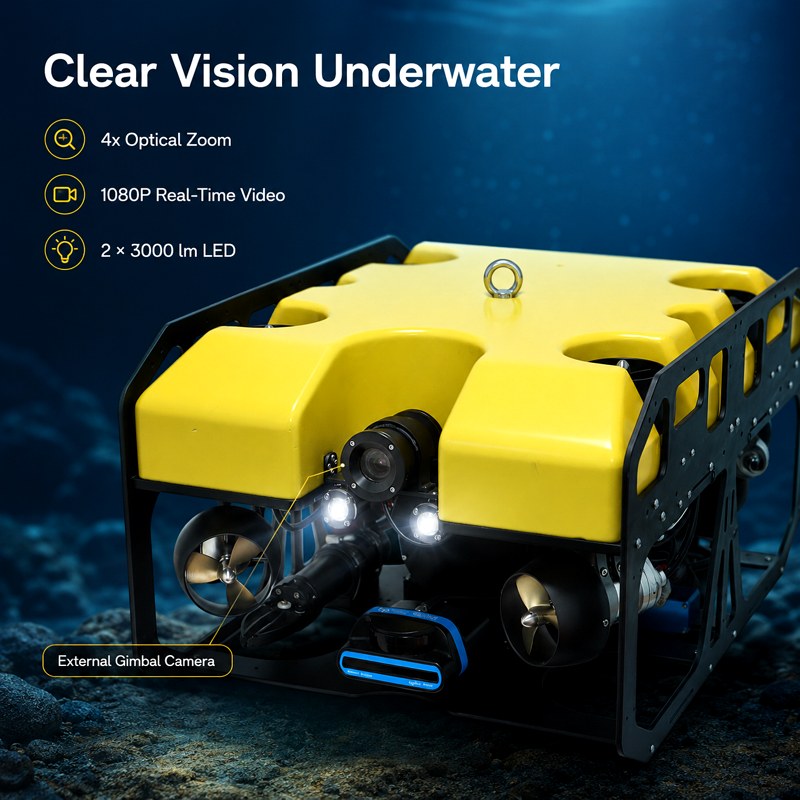
The 1080p low-light camera provides a 110-degree horizontal viewing angle, 4x optical zoom, and adjustable pitch from -90 to +90 degrees. Adjustable LED lights are rated at 3,000 lumens per light for viewing submerged objects.

04. Live Monitoring and Assisted Control

QGroundControl (QGC) displays live video, vehicle status, and operating parameters. In addition to manual operation, the R40 supports auto depth keeping and auto course keeping.

05. Modular Mission Equipment

The frame can accommodate compatible optional equipment such as a 360-degree scanning sonar, multibeam sonar, altimeter, thermometer, and current meter. Users can configure the payload for underwater infrastructure inspection, research, archaeology, and reservoir or port surveys.
product detail

product detail

product detail

product detail

Product Name XHX ROV R40 Shore-Powered Underwater Inspection and Survey Robot
Product Type Tethered Remotely Operated Underwater Vehicle
Power Supply Method Shore-Based Power Supply
Supply Voltage 220 VAC, 50 Hz
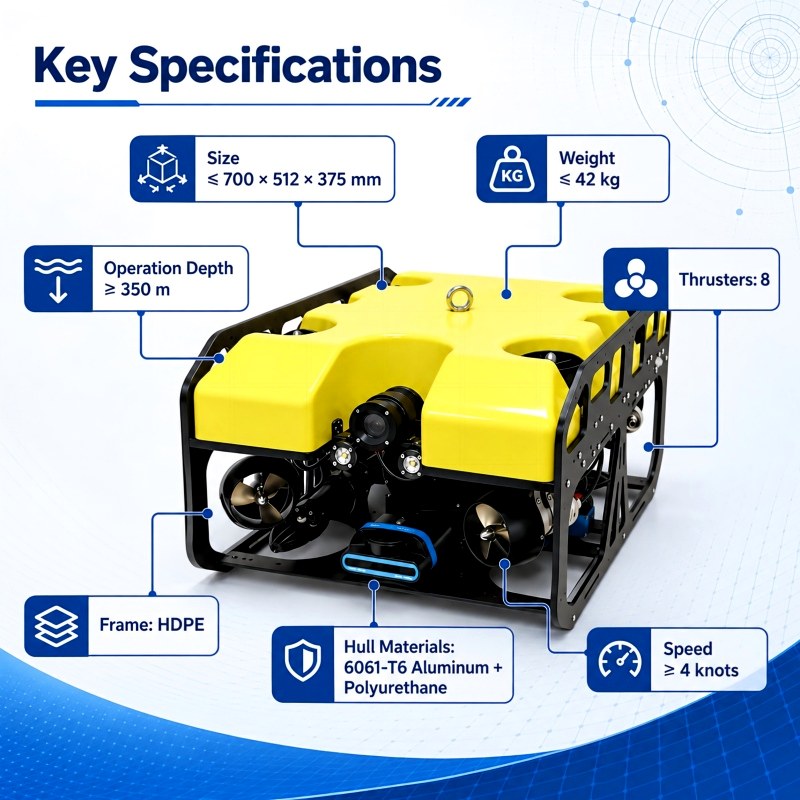
Dimensions (L × W × H) 700 × 512 × 375 mm
Weight 42 kg
Frame Material Aluminum Alloy
Electronic Cabin Material Aluminum Alloy
Battery Cabin Material Aluminum Alloy
Maximum Operating Depth 350 m
Maximum Forward Speed 2 m/s (approximately 4 knots)
Payload Capacity 5.6 kg
Thruster Configuration 8 T300S Thrusters; 4 Horizontal and 4 Vertical
Forward Thrust 35 kgf
Vertical Thrust 42 kgf
Lateral Thrust 25 kgf
Overall Thrust 50 kgf
Camera 1080p Low-Light Underwater Camera
Camera Sensor 5 Megapixels
Camera Horizontal Viewing Angle 110°
Camera Optical Zoom 4×
Camera Tilt Range Pitch ±90°
Underwater Lighting 2 Adjustable LED Lights
Light Brightness 3,000 Lumens per Light
Umbilical Cable Diameter 9.4 mm
Umbilical Cable Length 25–300 m
Cable Working Strength 100 kg
Cable Breaking Strength 300 kg
Control Software QGroundControl (QGC)
Control Modes Manual, Auto Depth Keeping, and Auto Course Keeping
Gyroscope 3-Axis
Accelerometer 3-Axis
Magnetometer 3-Axis
Depth Gauge B30
Leakage Sensor LD04
Freshwater Buoyancy Neutral
Seawater Buoyancy Slightly Positive
Optional Sensors Current Meter, Thermometer, Altimeter, 360° Scanning Sonar, and Multibeam Sonar

Get In Touch

Message lily01@xhx-tec.com +86 181 2608 7749