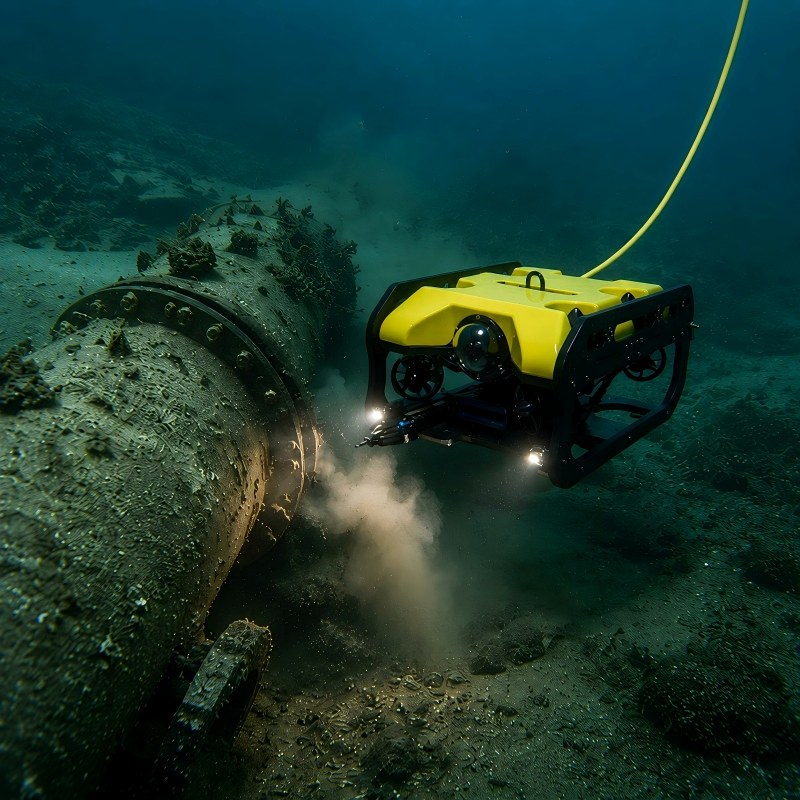
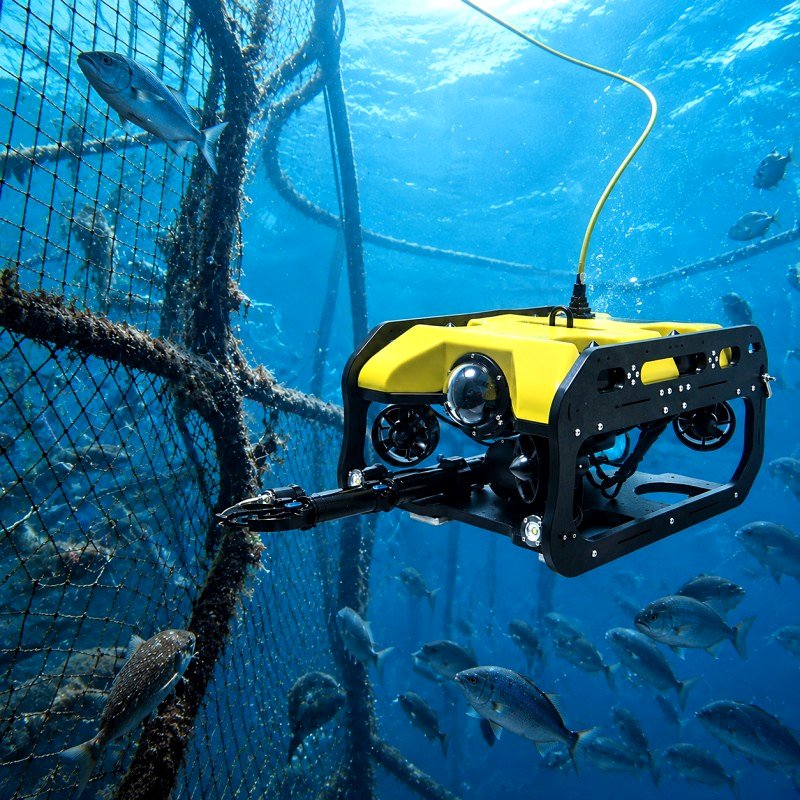
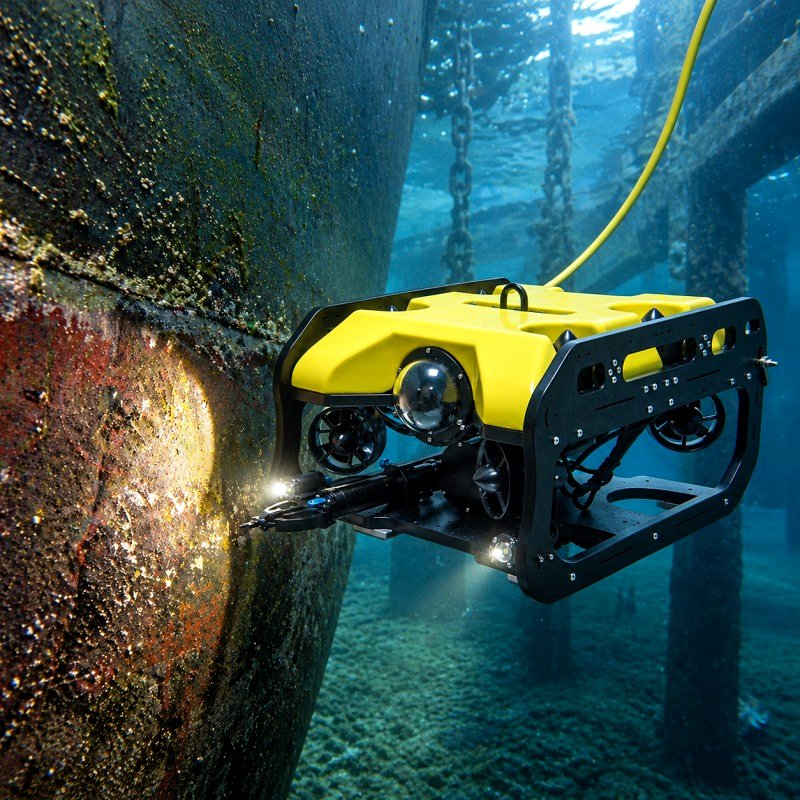
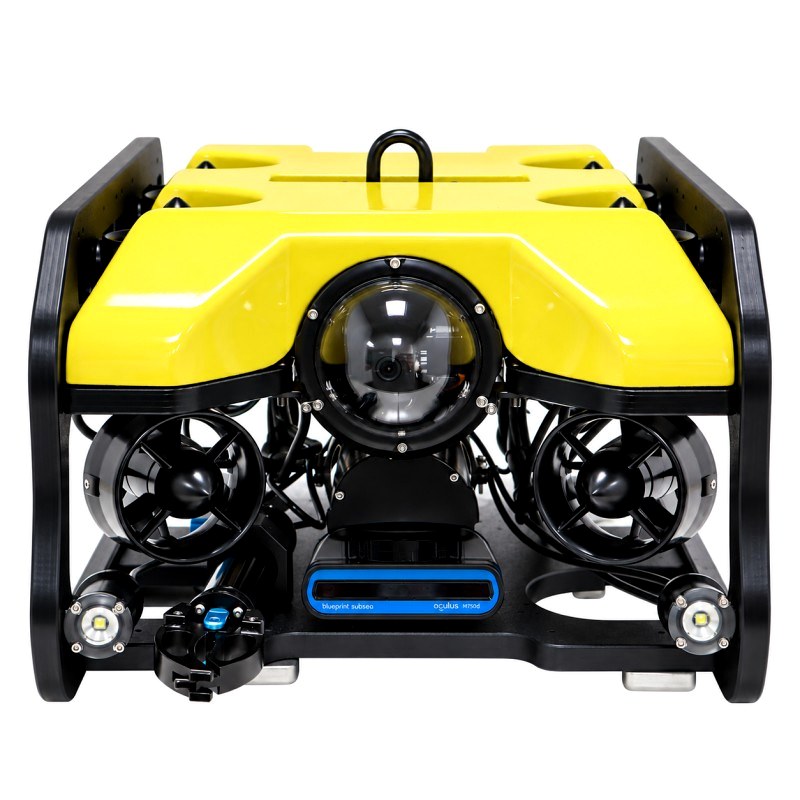
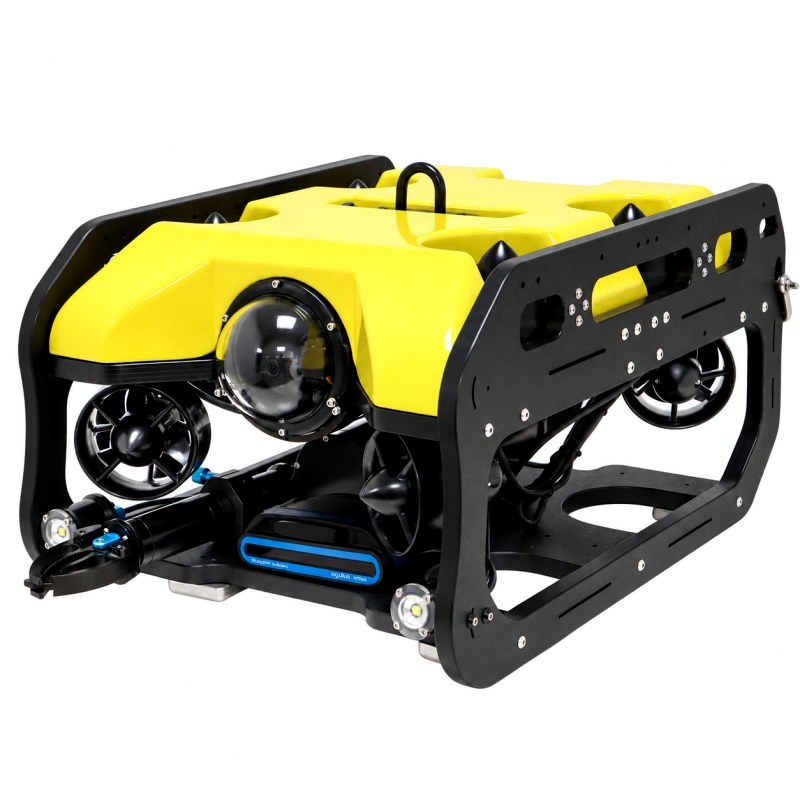
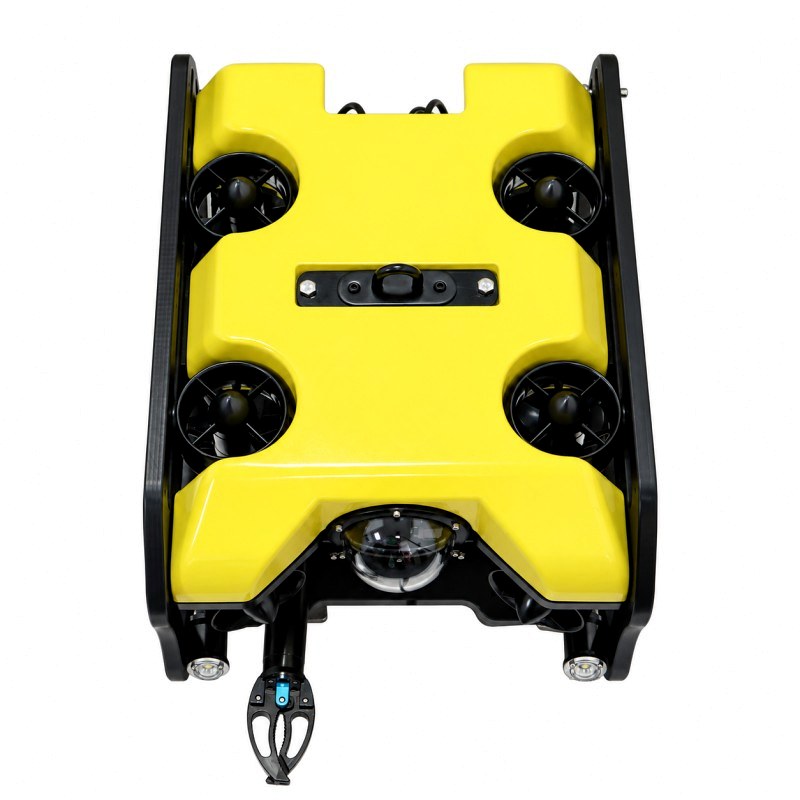
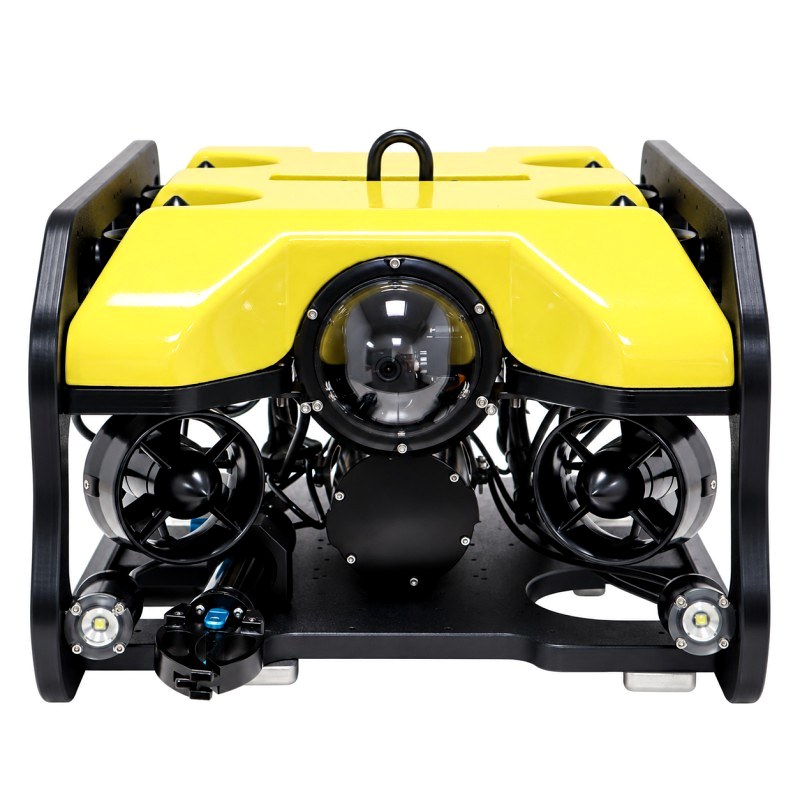
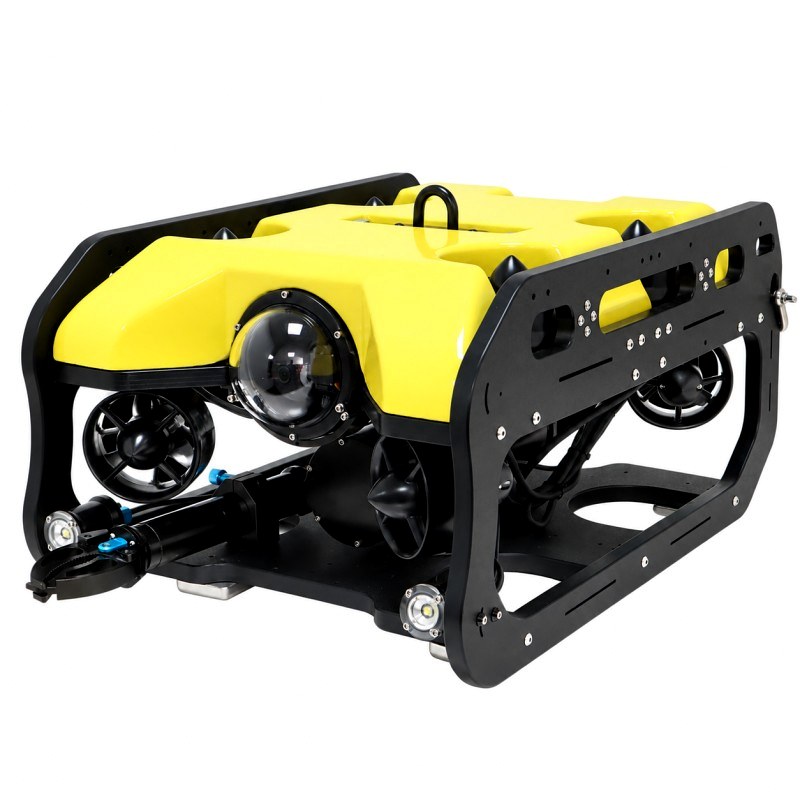
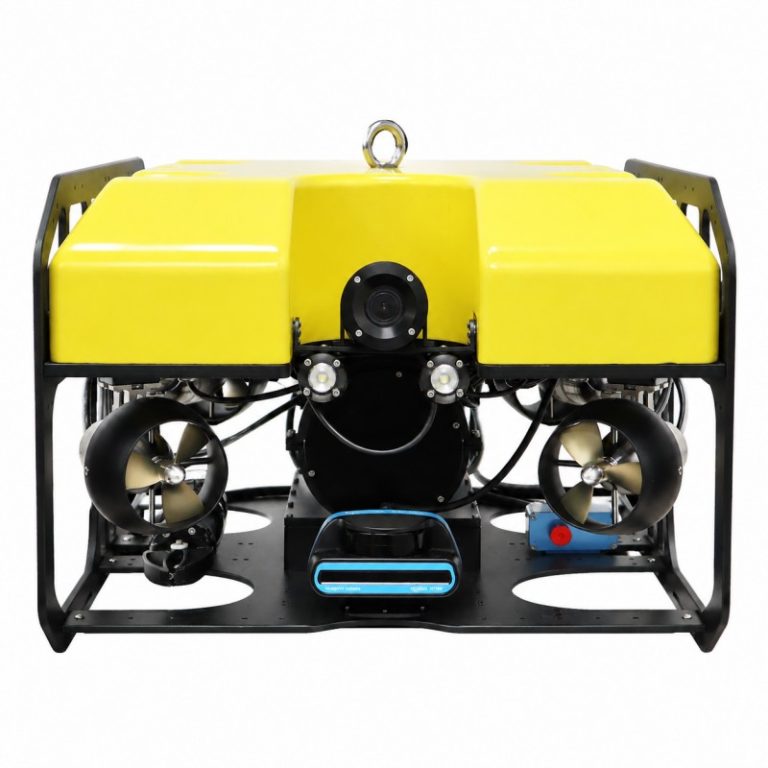
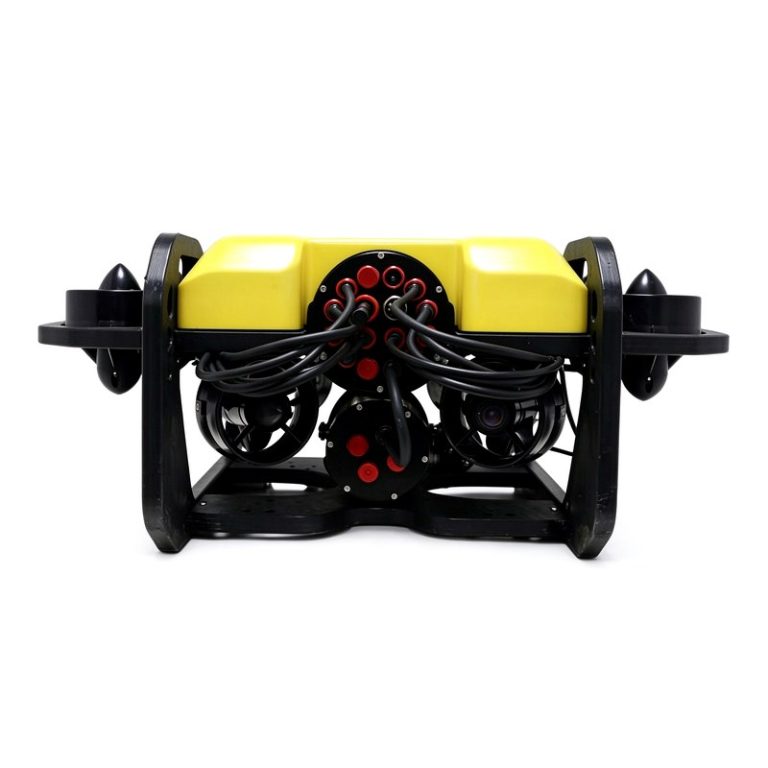
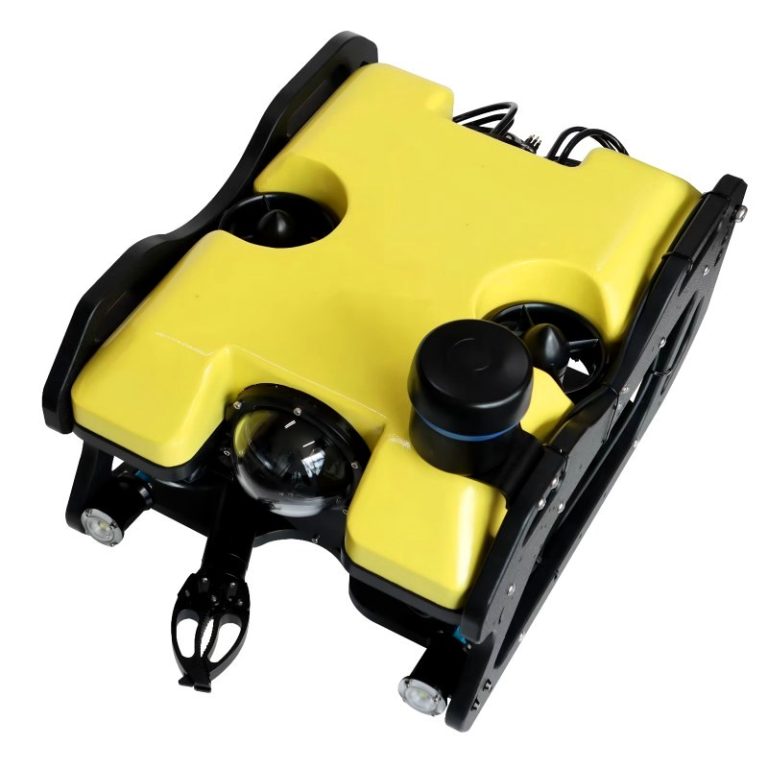
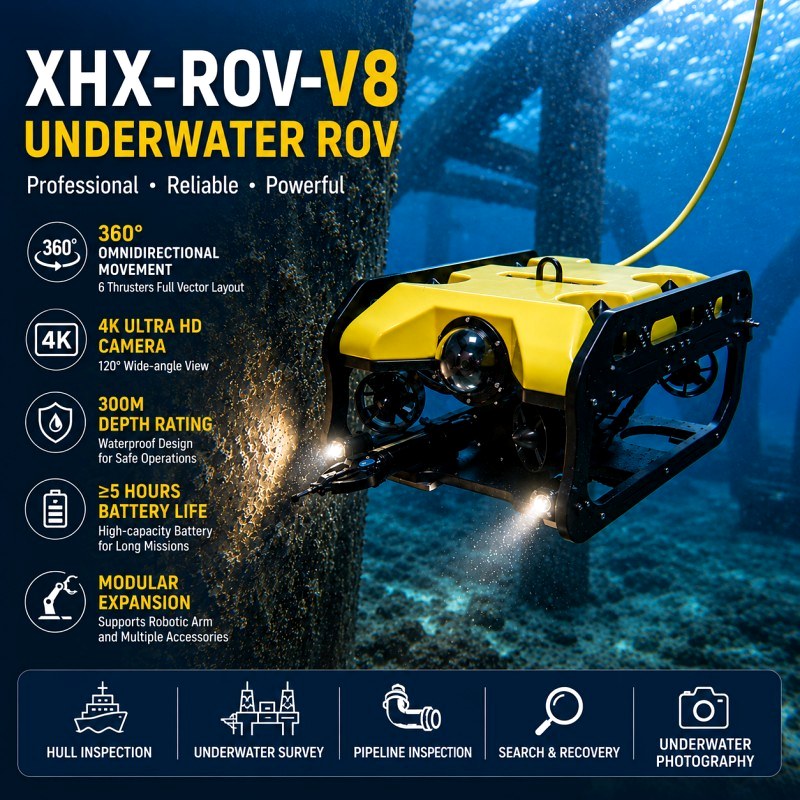
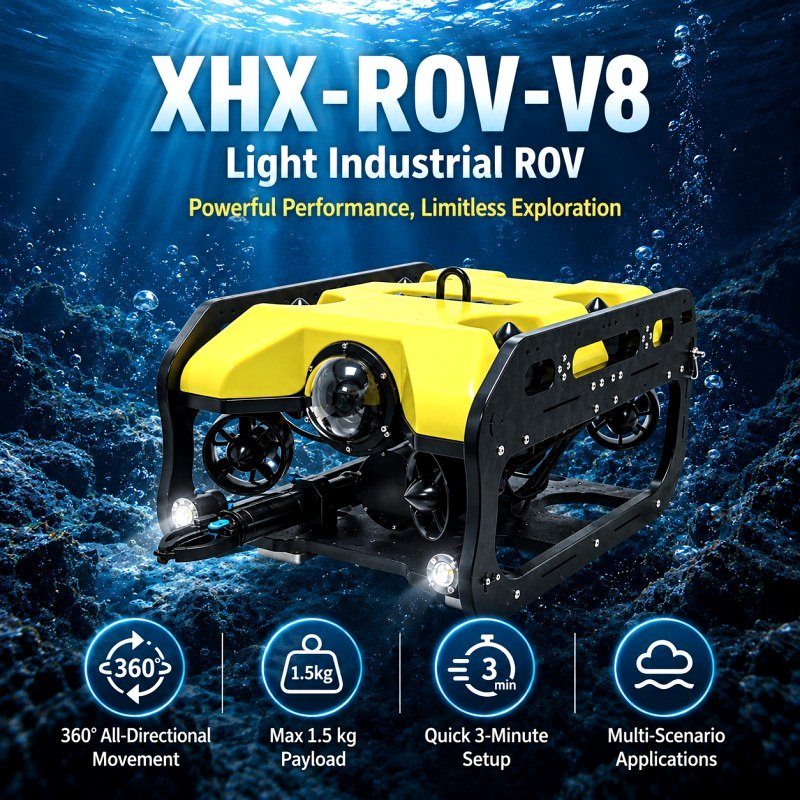
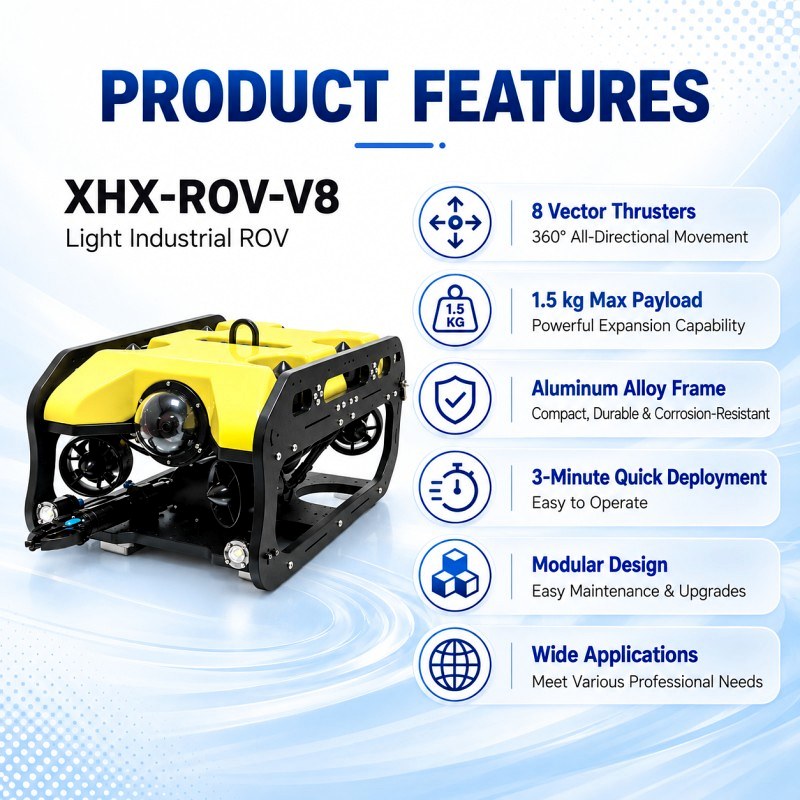
The XHX-ROV-V8 is a compact underwater ROV for inspection, search and rescue support, and field work. Its eight-thruster vector layout enables omnidirectional movement, while the camera, lighting, and sensor functions help operators observe and document underwater conditions.
Designed for Flexible Underwater Work
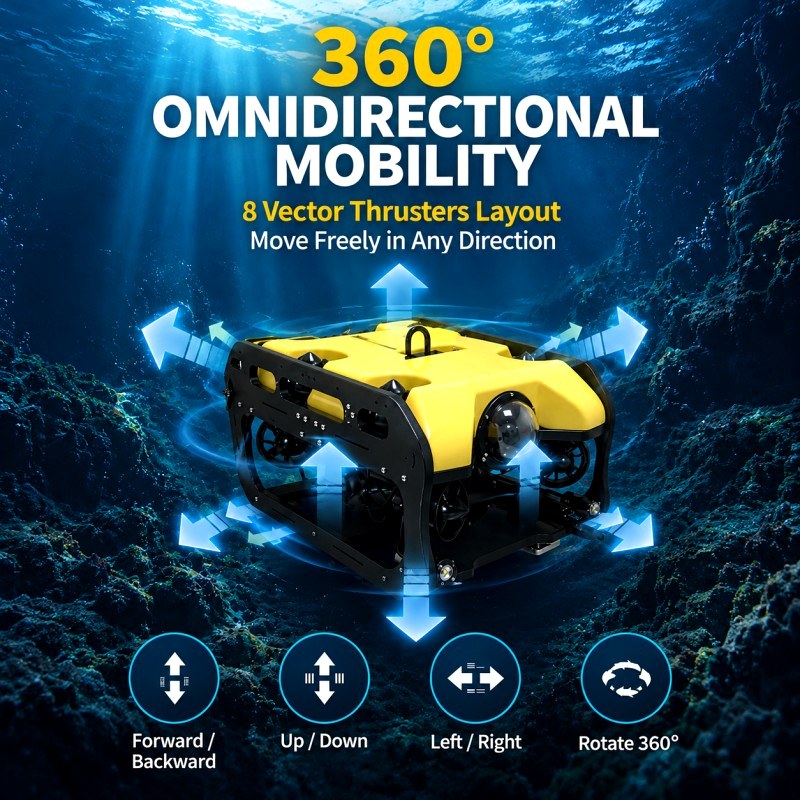
◉ Omnidirectional Control
Eight vector-arranged thrusters support forward, backward, lateral, vertical, and diagonal movement, helping the ROV approach targets in confined or complex locations.
◉ Quick Field Deployment
The compact aluminum-alloy platform is designed for preparation by one operator in approximately three minutes. Its removable battery can be exchanged between missions when additional charged batteries are available.
◉ Camera and Adjustable Lighting
The underwater camera is listed with 1080p video and a gimbal field of view of at least 160 degrees. Lighting provides up to 12,000 lumens with eight brightness levels to support observation in different visibility conditions.
◉ Payload Options for the Task
The stated maximum payload is 1.5 kg. Compatible accessory options include a robotic arm for underwater gripping and handling tasks and sonar equipment; select accessories to match the vehicle’s payload and compatibility requirements.
◉ Real-Time Mission Information
The ROV can record depth and temperature data in real time. These readings complement the camera view during hull and dock inspection, aquaculture work, scientific exploration, and underwater photography.
Confirm working depth, tether length, payload, accessory compatibility, and local conditions before deployment. Actual performance depends on configuration, water conditions, visibility, current, and operating technique.
| Product Name |
XHX-ROV-V8 Underwater ROV |
| Product Type |
Compact Industrial Underwater Remotely Operated Vehicle |
| Primary Applications |
Underwater search and rescue support, hull and dock inspection, aquaculture inspection, scientific exploration, and underwater photography |
| Body Material |
Aluminum alloy |
| Dimensions |
550 × 400 × 280 mm |
| Weight |
20 kg |
| Maximum Operating Depth |
350 m |
| Maximum Speed |
2 m/s (approximately 4 knots) |
| Operating Endurance |
≥6 hours |
| Battery Capacity |
18 Ah |
| Battery Design |
Removable and replaceable battery |
| Operating Temperature |
−10°C to 40°C |
| Thruster Configuration |
8 thrusters, including 4 vector-arranged horizontal thrusters and 4 vertical thrusters |
| Movement |
360-degree omnidirectional movement |
| Vertical Thruster Force |
≥25 kgf |
| Lateral Thruster Force |
16 kgf |
| Maximum Stated Payload |
1.5 kg |
| Towing Force |
≥15 kg |
| Camera Video Resolution |
1080p |
| Camera Field of View |
≥160° |
| Lighting |
4 × 3,000-lumen LED lights, 12,000 lumens total |
| Lighting Control |
8 adjustable brightness levels |
| Sensors |
IMU, accelerometer, gyroscope, electronic compass, temperature sensor, depth sensor, water-ingress detection sensor, and current meter |
| Depth Sensor Accuracy |
<±0.25 m |
| Temperature Sensor Accuracy |
<±2°C |
| Tether |
Kevlar neutral-buoyancy communication cable |
| Standard Tether Length |
≥200 m; customizable |
| Tether Diameter |
6–9.5 mm; customizable |
| Tether Breaking Strength |
≥260 kg |
| Ground Station |
Dual-screen, 10-point touch control system |
| Ground Station Screens |
Main screen ≥15.6 inches; secondary screen ≥11.6 inches |
| Ground Station Storage |
≥128 GB, expandable up to 512 GB |
| Ground Station System |
Windows 10 with ROV control software |
| Optional Accessories |
Robotic arm and compatible sonar equipment |
| Robotic Arm Opening Width |
140 mm |
| Robotic Arm Gripping Force |
220 N |
| Robotic Arm Opening Angle |
≥80° |
| Robotic Arm Operating Weight |
≤370 g in air; ≤50 g underwater |
| Additional Functions |
One-key depth holding, real-time depth and temperature recording, accessory expansion, and anti-sand-jamming motor design |