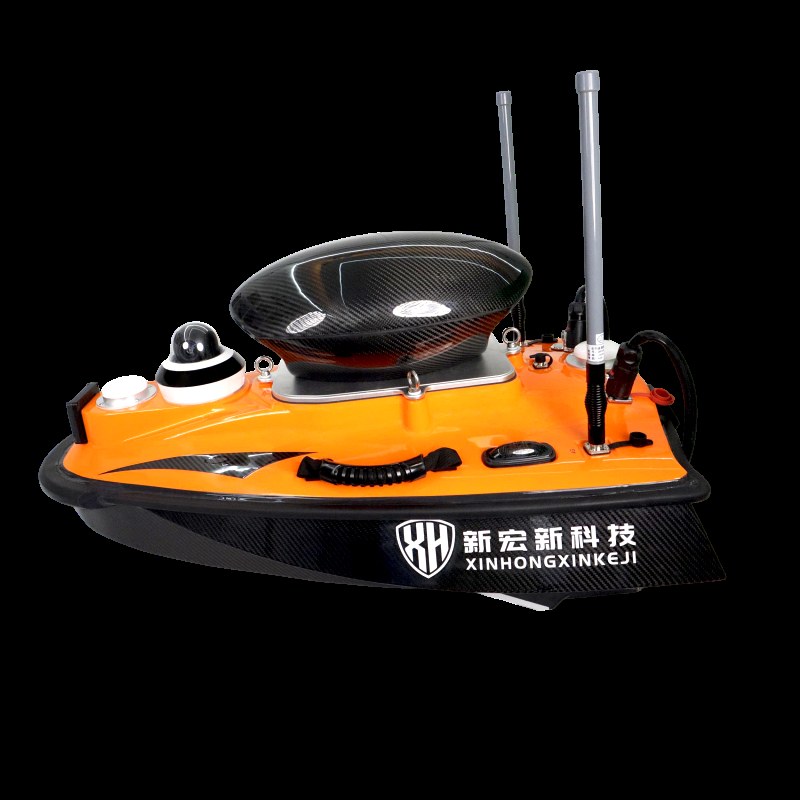
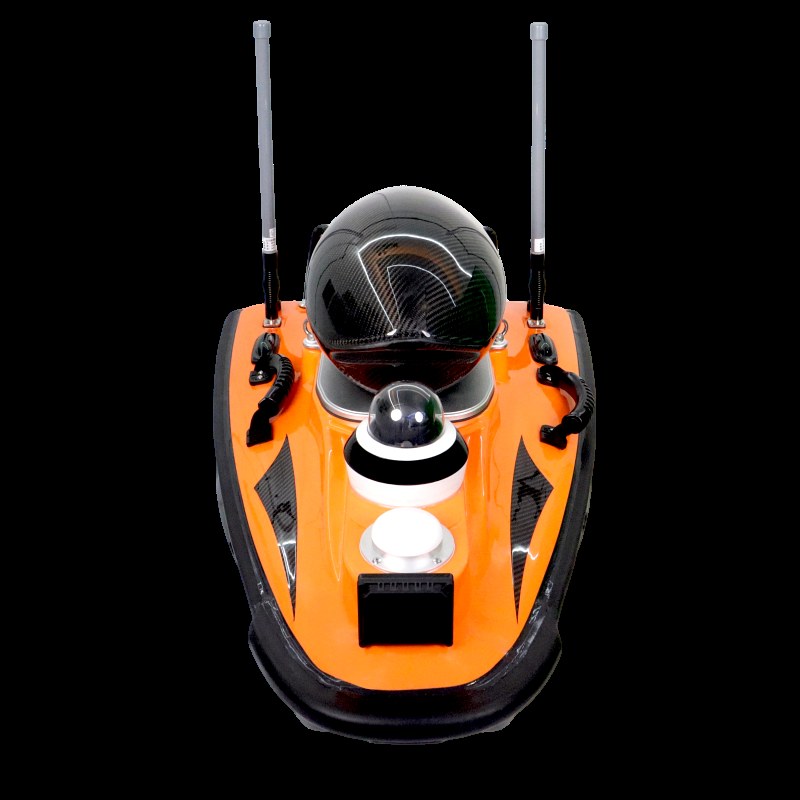
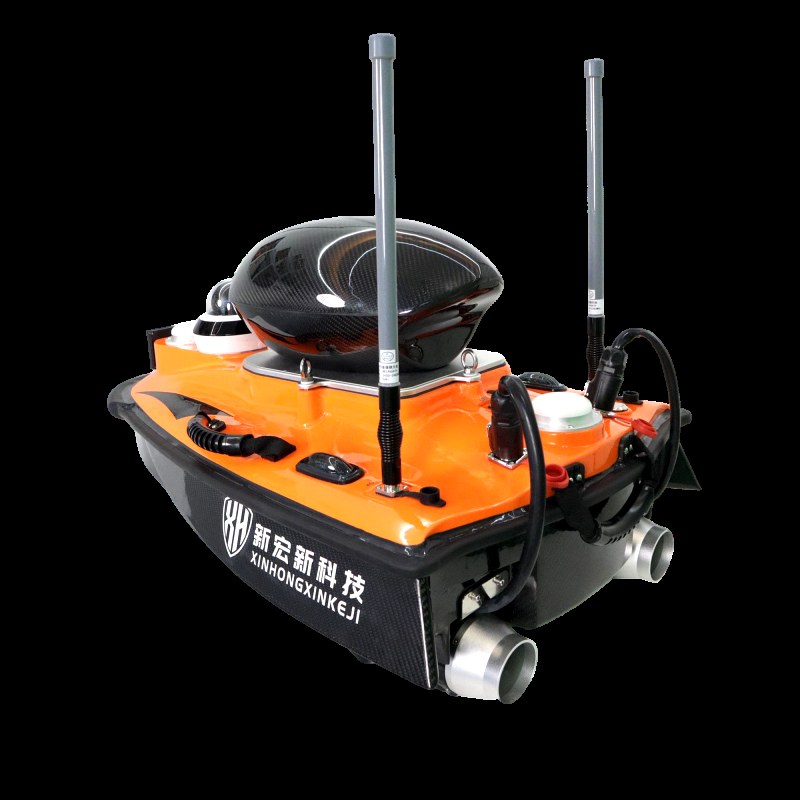
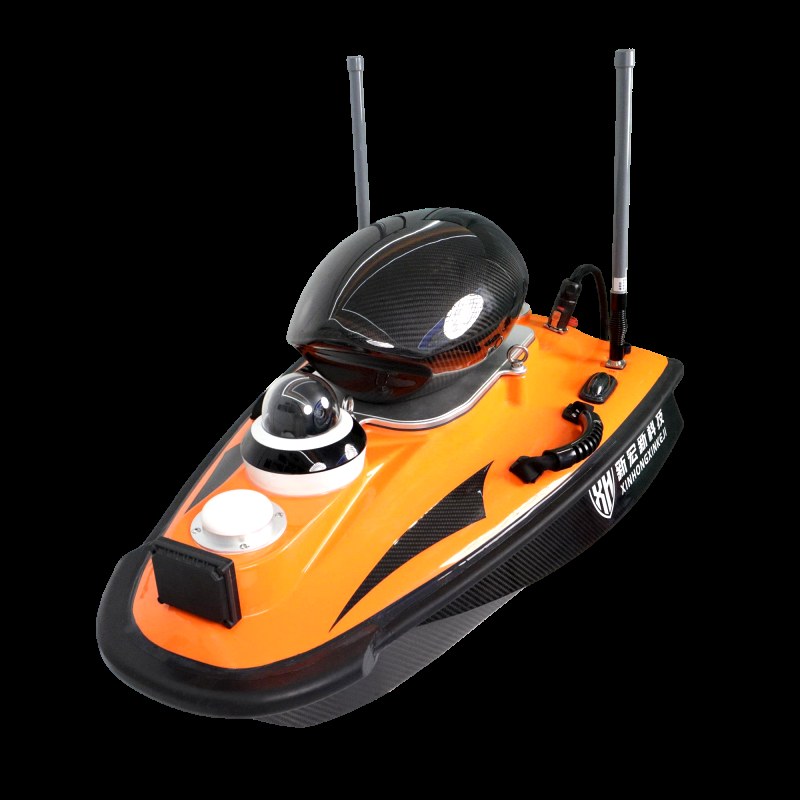
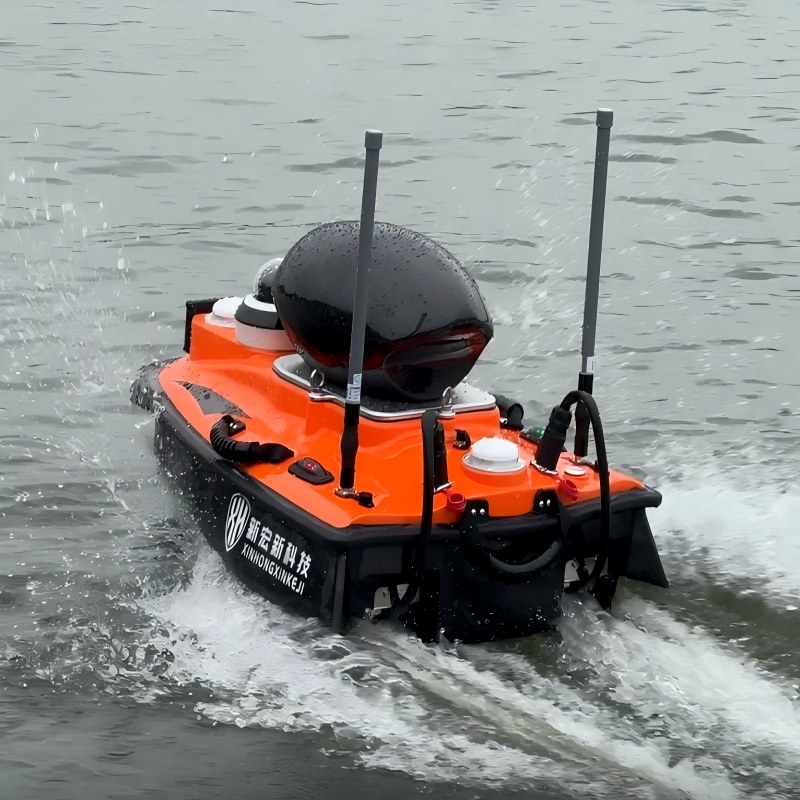
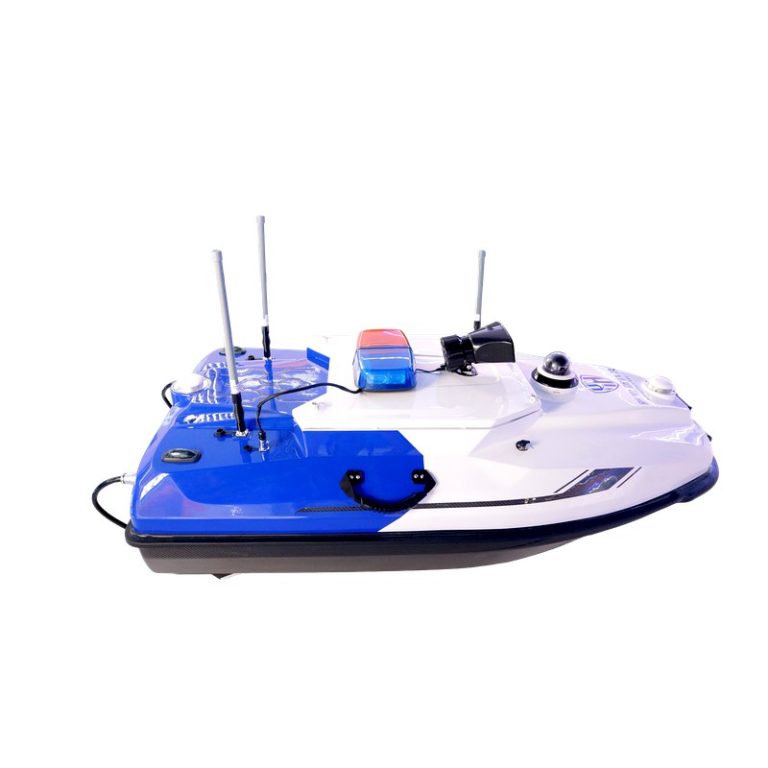
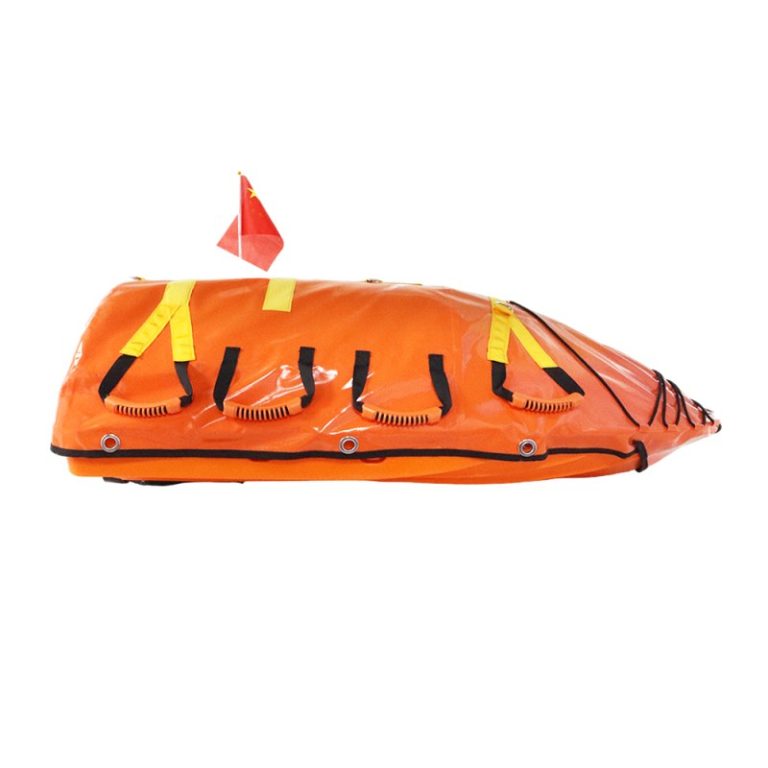
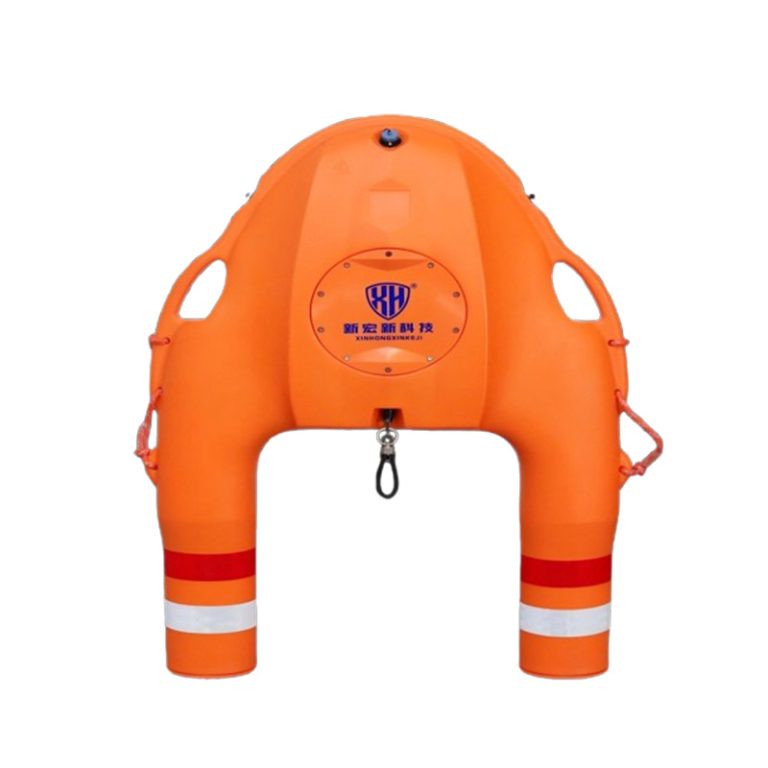
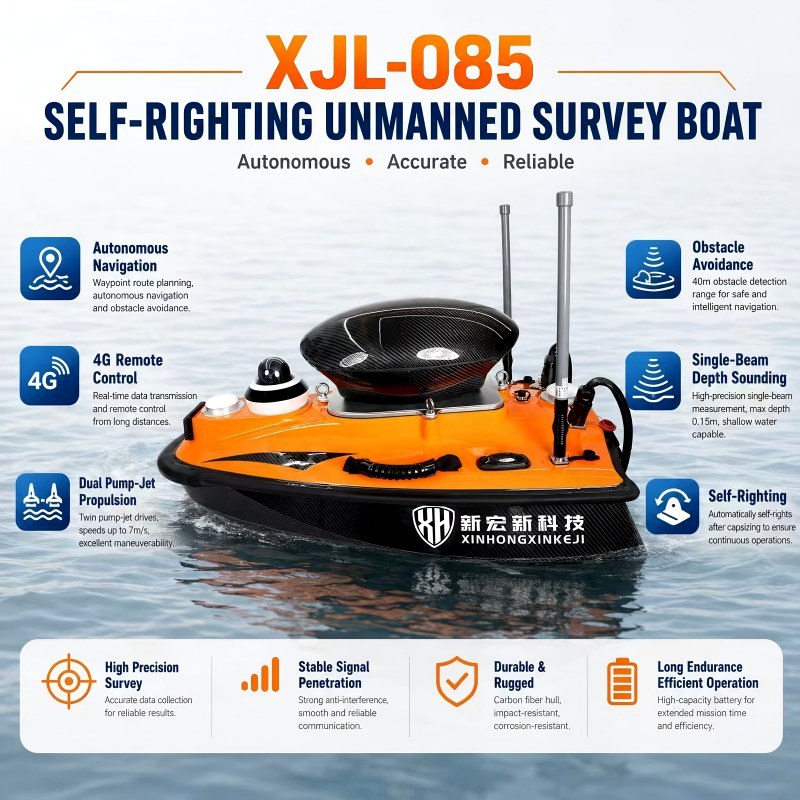
The Self-Righting Unmanned Surface Vessel is a remote-controlled boat designed for water patrol and monitoring missions. With a self-righting hull and durable construction, it can operate in challenging water conditions and recover upright after capsizing.
Key Features
01. Self-Righting Hull Design
Geometrically stable hull returns to upright position if capsized, allowing continuous operation in rough water, high winds, or after impact. Minimizes mission abort due to capsize events.
02. Remote-Controlled Patrol
Designed for waterway monitoring, surveillance, and patrol missions. Operators can navigate the vessel remotely to inspect bridges, shorelines, reservoir areas, and restricted zones.
03. Durable and Reliable
Built for extended surface operations with a robust hull suitable for freshwater and coastal environments. Supports various payload configurations for observation and data collection tasks.
| Product Name |
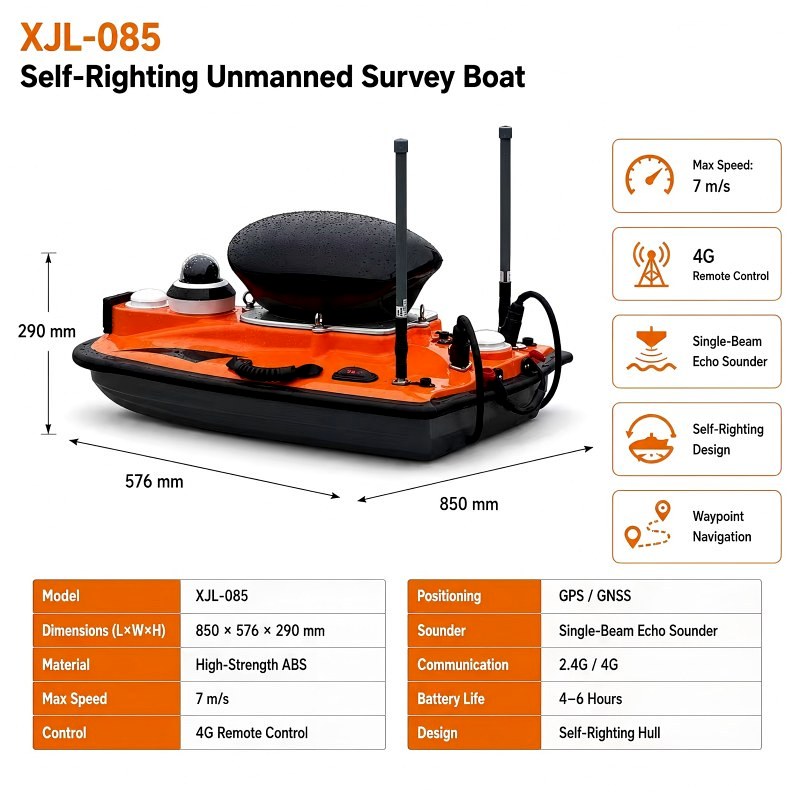
Self-Righting Unmanned Surface Vessel |
| Model |
XJL-085 |
| Manufacturer |
Shenzhen Xinhongxin Technology Co., Ltd. |
| Country of Origin |
China |
| Hull Configuration |
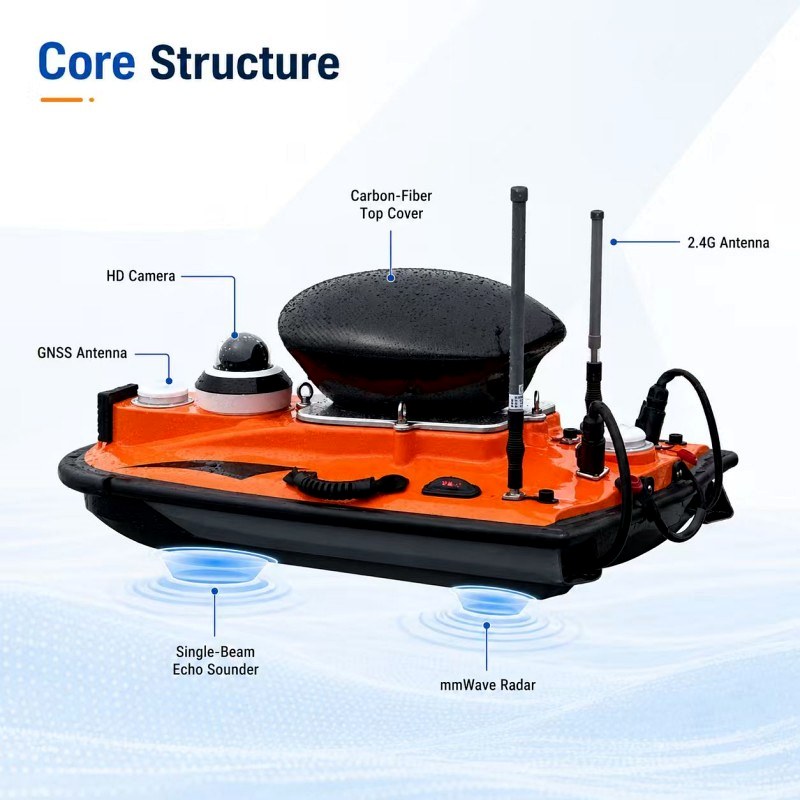
M-Shaped Hull with a Removable Upper Cover |
| Hull Dimensions |
850 × 576 × 290 mm |
| Hull-Shell Weight |
3 kg |
| Maximum Payload |
25 kg |
| Hull Materials |
Polymer/Polyester, Carbon Fiber, and Kevlar |
| Self-Righting Structure |
Upper Buoyancy Compartment Designed to Restore Upright Orientation After Capsizing |
| Hull Protection Rating |
IP68 |
| Main Control Unit Protection |
IP67 |
| Specified Operating Conditions |
Wind Level 3 and Wave Level 2 |
| Maximum Vessel Speed |
7.0 m/s |
| Specified Endurance |
3 Hours at 2 m/s |
| Battery Configuration |
Two Rechargeable 20 Ah Battery Units Using 21700 Cells |
| Propulsion System |
Twin Ducted Pump-Jet Thrusters |
| Motor Type |
Sensorless Brushless DC Motor |
| Specified Propulsion Operating Voltage |
33 V |
| Rated Propulsion Power |
2 × 1000 W |
| Maximum Motor Speed |
6000 rpm |
| Thruster Dimensions |
320 × 96 × 111.5 mm |
| Thruster Mounting |
Plug-In Design for Removal and Replacement |
| Control Modes |
Manual Remote Control and Autonomous Navigation |
| Waypoint Capacity |
Up to 512 Waypoints per Planned Navigation Task |
| Cruise Function |
Constant-Speed Navigation with Operator Directional Control |
| Station Keeping |
Supports Position Holding; Current-Speed Limits Are Not Specified |
| Obstacle Avoidance |
Millimeter-Wave Radar for Forward Obstacle Avoidance During Autonomous Navigation and Return |
| Return Functions |
Operator-Initiated Return, Communication-Loss Return, Low-Battery Return, and Mission-Completion Return |
| Radio Control Distance |
Up to 2 km, Subject to Operating Conditions |
| Radio Frequency |
2.4 GHz |
| Cellular Communication |
Standard 4G Connectivity; 5G Requires Configuration |
| Remote Controller Dimensions |
272 × 183 × 94 mm |
| Controller Interface |
Touchscreen with an Android Application |
| Controller Endurance |
Specified as 6–20 Hours |
| Video Functions |
Panoramic Video Monitoring and Photography |
| Positioning |
GNSS Positioning with BeiDou Support |
| Navigation Logs |
Rolling Storage of the Most Recent 50 Navigation Records |
| Data Handling |
Local Storage with Support for Multichannel and Remote Storage |
| Software Functions |
Mission Planning, Route Monitoring, Data Acquisition, Data Post-Processing, Coordinate Conversion, and Result Export |